Robotic arms and automated guided systems demand sub-millimeter precision. Whether guiding a spot welder, picking microscopic components, or inspecting solder joints, a robot relies entirely on its imaging pipeline. Software algorithms can only process the optical data they receive. If the incoming image is blurred, distorted, or misaligned, even the most advanced neural network fails.
Selecting the right robots CCTV lens bridges the gap between mechanical execution and optical reality. At Jinyuan, we help automation teams specify industrial optics built to withstand high-g accelerations while delivering crisp edge-to-edge resolution.
If you are drafting an automation project or upgrading an existing production line, contact our engineering team early. Securing the right optical specifications during the design phase prevents costly retrofits and downtime.
What Exactly Is a Robots CCTV Lens?
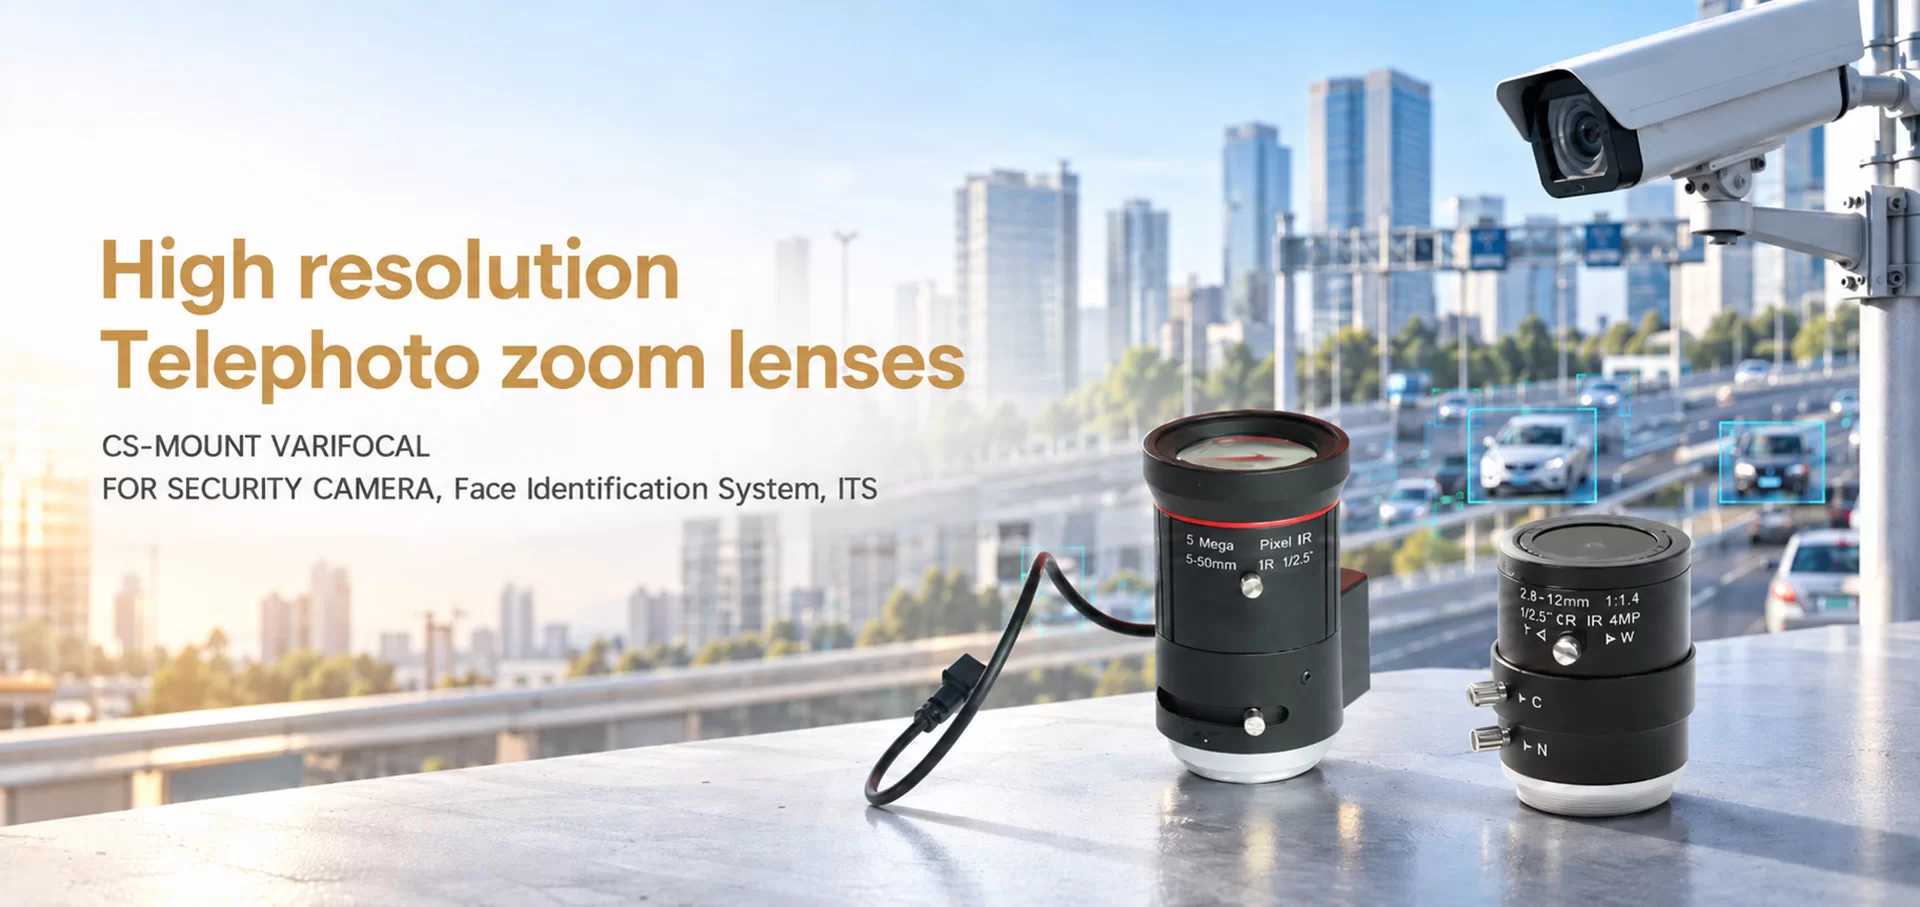
A standard CCTV lens designed for building security will not survive on a robot. Consumer security lenses use lightweight plastic housings, loosely fitted glass elements, and non-locking focus rings. Under the rapid stops and starts of an articulated arm, their internal components shift, ruining calibration.
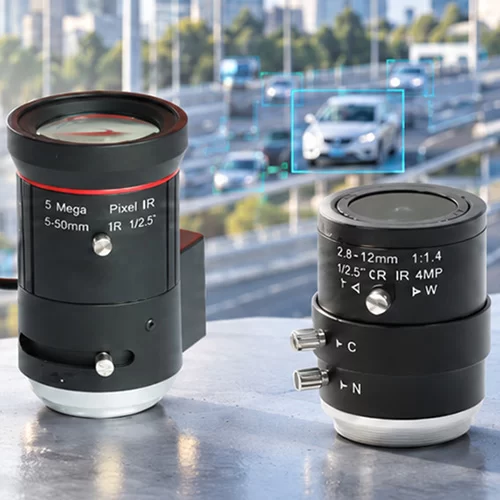
A true industrial CCTV lens for robotics features all-glass optics, metal barrels, and mechanical locking screws for both aperture and focus. These lenses balance compact physical dimensions with tight optical tolerances.
Compared to bulky telecentric lenses, an industrial CCTV lens offers a lighter payload and a more flexible working distance. It provides the high optical resolution and low distortion required for measurement while fitting neatly onto tight end-effectors.
4 Critical Optical Parameters for High-Precision Robotic Vision
To choose the correct lens, you must evaluate four foundational optical specifications against your mechanical envelope.
1. Low Optical Distortion
Optical distortion displaces pixels away from their geometrically correct positions. In robotic guidance, barrel or pincushion distortion turns straight reference edges into curves, throwing off coordinate calculations.
- Optical Distortion: Physical deviation caused by lens element geometry.
- TV Distortion: Standardized measurement defined by industrial standards (R/H percentage).
For high-precision assembly, look for an industrial CCTV lens with less than 0.1% or 0.2% distortion. While software calibration grids can correct distortion computationally, physical correction at the lens level preserves native edge contrast and saves processing cycles.
2. Resolution and Sensor Format Matching
Lenses and image sensors must match in size and resolving power. If you place a small-format lens (like 1/2") on a larger sensor (such as 2/3" or 1"), the edges of the image will suffer from severe light drop-off and vignetting.
The lens must cover the sensor's entire image circle. Furthermore, ensure the megapixel rating of the lens matches the pixel pitch of your sensor. A 10-megapixel sensor paired with a budget 2-megapixel lens results in wasted sensor resolution and soft, unusable feature edges.
3. Field of View (FOV) and Working Distance (WD)
Field of view describes the target area the camera inspects. Working distance is the physical gap between the front lens element and the workpiece. These two values dictate your focal length.
You can calculate the required focal length ($f$) using this standard formula:
Focal Length (mm) = (Sensor Dimension × Working Distance) / Field of View
Be conservative with your working distance calculations. Ensure mechanical tooling, grippers, and safety clearances do not block the field of view during cycle movements.
4. Aperture (F-Stop) and Depth of Field (DOF)
The aperture ring controls light intake and depth of field. A wide-open aperture (such as f/1.4) allows more photons onto the sensor, enabling faster shutter speeds. However, it significantly thins the depth of field.
If a robotic arm inspects parts of varying heights, a shallow depth of field causes tall features to blur. Closing the aperture to f/5.6 or f/8 expands the in-focus zone, but it demands brighter auxiliary machine vision lighting to maintain exposure speeds.
Robot-Specific Ruggedization Factors
Optical purity means nothing if the lens loses focus after three production cycles. High-speed automation puts extreme mechanical stress on vision components.
Vibration and Shock Resistance
Six-axis articulated robots experience sudden jerks, rotational torque, and continuous micro-vibrations. Standard manual lenses feature friction rings that slide out of position within hours.
Industrial lenses solve this with recessed steel locking screws on both the focus and iris barrels. For harsh settings, consider ruggedized lenses with fixed internal elements glued into place to eliminate optical drift entirely.
Weight and Payload Limits
Every gram mounted to an end-effector impacts the robot's cycle time and motor strain. Adding heavy telecentric glass reduces maximum joint acceleration.
Compact robots CCTV lenses manufactured by Jinyuan utilize lightweight aircraft-grade aluminum. They minimize end-of-arm inertia without sacrificing thermal stability or structural rigidity.
Thermal Stability
Machining centers, welding cells, and foundries expose vision gear to shifting temperatures. Thermal expansion shifts optical focus. Quality industrial optics incorporate thermal compensation designs to maintain sharpness across broad operational temperature bands.
A 5-Step Selection Framework for System Integrators
Follow this systematic procedure to prevent costly component mismatches during vision cell design:
Step 1: Define Measurement Tolerance
Start with the engineering tolerance of the part. If you must inspect a component within ±0.02 mm, your imaging resolution must provide at least three to four pixels per tolerance unit. This calculation defines your minimum camera resolution.
Step 2: Establish Working Distance and FOV
Map out the mechanical envelope of the robot cell. Measure the space between the lens face and the object at full stroke. Determine the minimum area the camera must see to capture all locating marks.
Step 3: Select the Mount and Sensor Format
Pick a camera sensor that delivers your target resolution. Then, verify the mount interface. Most industrial CCTV lenses use standard C-mount (17.526 mm flange distance) or CS-mount (12.52 mm flange distance). Ensure your lens mount matches the camera body.
Step 4: Assess Environmental Stresses
Will the robot experience 5G rapid stops? Are there oil mists, coolants, or welding sparks? Select optics with robust IP-rated seals, ruggedized locking screws, and protective front optical windows if the cell runs aggressive processes.
Step 5: Run Laboratory Calibration Tests
Never send a lens into production without bench testing. Test the optics using an optical target (like a Ronchi ruling or checkerboard chart). Calibrate the distortion profile and confirm focus consistency across the complete field of view.
Real-World Applications
Different automated cells place contrasting priorities on lens design:
3D Pick-and-Place Systems
Bin-picking arms require high depth of field to locate parts piled haphazardly inside deep containers. Integrators frequently use short focal length lenses (8 mm to 12 mm) with closed apertures, backed by structured laser or high-intensity LED illumination.
Semiconductor and SMT Assembly
Placing micro-BGA chips requires micron-level accuracy. Here, low optical distortion takes priority. System builders employ 25 mm to 50 mm focal length lenses with low aberration coatings to resolve tiny fiducial marks on printed circuit boards.
Autonomous Mobile Robots (AMR)
Mobile platforms navigate warehouses with moving obstacles and dynamic ambient lighting. These systems demand wide-angle, ruggedized CCTV lenses paired with auto-iris capabilities or high dynamic range sensors to manage shifting ceiling lights.
Common Selection Mistakes to Avoid
Even seasoned systems engineers fall into these classic optical traps:
- Prioritizing Megapixels over Optical Glass Quality: A cheap 12-megapixel lens often yields softer images than a high-grade 5-megapixel lens with superior contrast (MTF) performance.
- Using Security Surveillance Optics: Consumer CCTV lenses suffer from loose focus rings and plastic threads. They cannot withstand machine vibration.
- Forgetting Working Distance Margins: Designing a system right at the minimum focus distance of a lens often introduces severe spherical aberration and edge blur.
- Ignoring Wavelength Compatibility: If you use narrow-band infrared illumination to cut through ambient factory glare, ensure your lens features anti-reflective coatings matched to that exact wavelength.
Frequently Asked Questions
Q1: Can I use a standard security CCTV lens for robotic
vision?
A1: No. Standard security lenses use plastic components,
lack locking screws, and suffer from high optical distortion. They quickly lose
focus under robotic motion and cannot provide the edge-to-edge sharpness needed
for precise industrial measurement.
Q2: What is the ideal focal length for a robotic arm vision
system?
A2: There is no single ideal focal length. It depends
entirely on your required Field of View, working distance, and sensor size.
Common robotic arm applications typically deploy lenses between 8 mm and 25 mm
to balance payload limits with inspection breadth.
Q3: How do vibration-proof CCTV lenses maintain focus during robotic
movement?
A3: Industrial anti-vibration lenses use mechanical
locking screws that lock the focus and aperture mechanisms directly to the inner
metal chassis. Extreme-duty versions use glued, fixed-focal optical assemblies
that contain zero moving parts.
Q4: What is the difference between C-mount and CS-mount lenses in
robotics?
A4: The primary difference is the flange focal distance.
C-mount lenses sit 17.526 mm away from the sensor plane, while CS-mount lenses
sit 12.52 mm away. You can mount a C-mount lens on a CS-mount camera using a 5
mm spacer, but you cannot mount a CS-mount lens on a C-mount camera.
Q5: Why does optical distortion matter if software can correct
it?
A5: Software correction stretches and interpolates pixel data to
straighten lines, which degrades image sharpness and lowers native resolution
near the corners. Starting with a low-distortion lens preserves raw optical data
and frees up processing cycles for the robot controller.
Build Better Robotic Vision Systems
A reliable machine vision system begins with quality glass. Pairing your industrial camera with the appropriate robots CCTV lens guarantees consistent data, stable cycle speeds, and minimal downtime across the life of your automated cell.
Jinyuan designs and manufactures rugged optical assemblies, machine vision lenses, and industrial components tailored to dynamic robotic platforms. Whether you need a low-distortion lens for micro-assembly or a vibration-proof solution for high-speed pick-and-place arms, our team is ready to assist.
Need help selecting the perfect lens for your robotic vision project? Contact Jinyuan today to speak directly with an optical engineer, discuss your system specifications, or request optical evaluation samples for your test lab.